
Arduino Based Autonomous Obstacle Avoiding Robot
Project Overview
This project outlines the design and development of a fully autonomous mobile robot engineered to navigate dynamic environments safely without human intervention. Utilizing ultrasonic distance sensing and real-time data processing, the system dynamically alters its trajectory to avoid physical collisions. This robot serves as a practical demonstration of embedded systems and automation, mirroring the foundational technology used in industrial automated guided vehicles (AGVs), smart home robotics, and surveillance systems.
Key Components & Tools
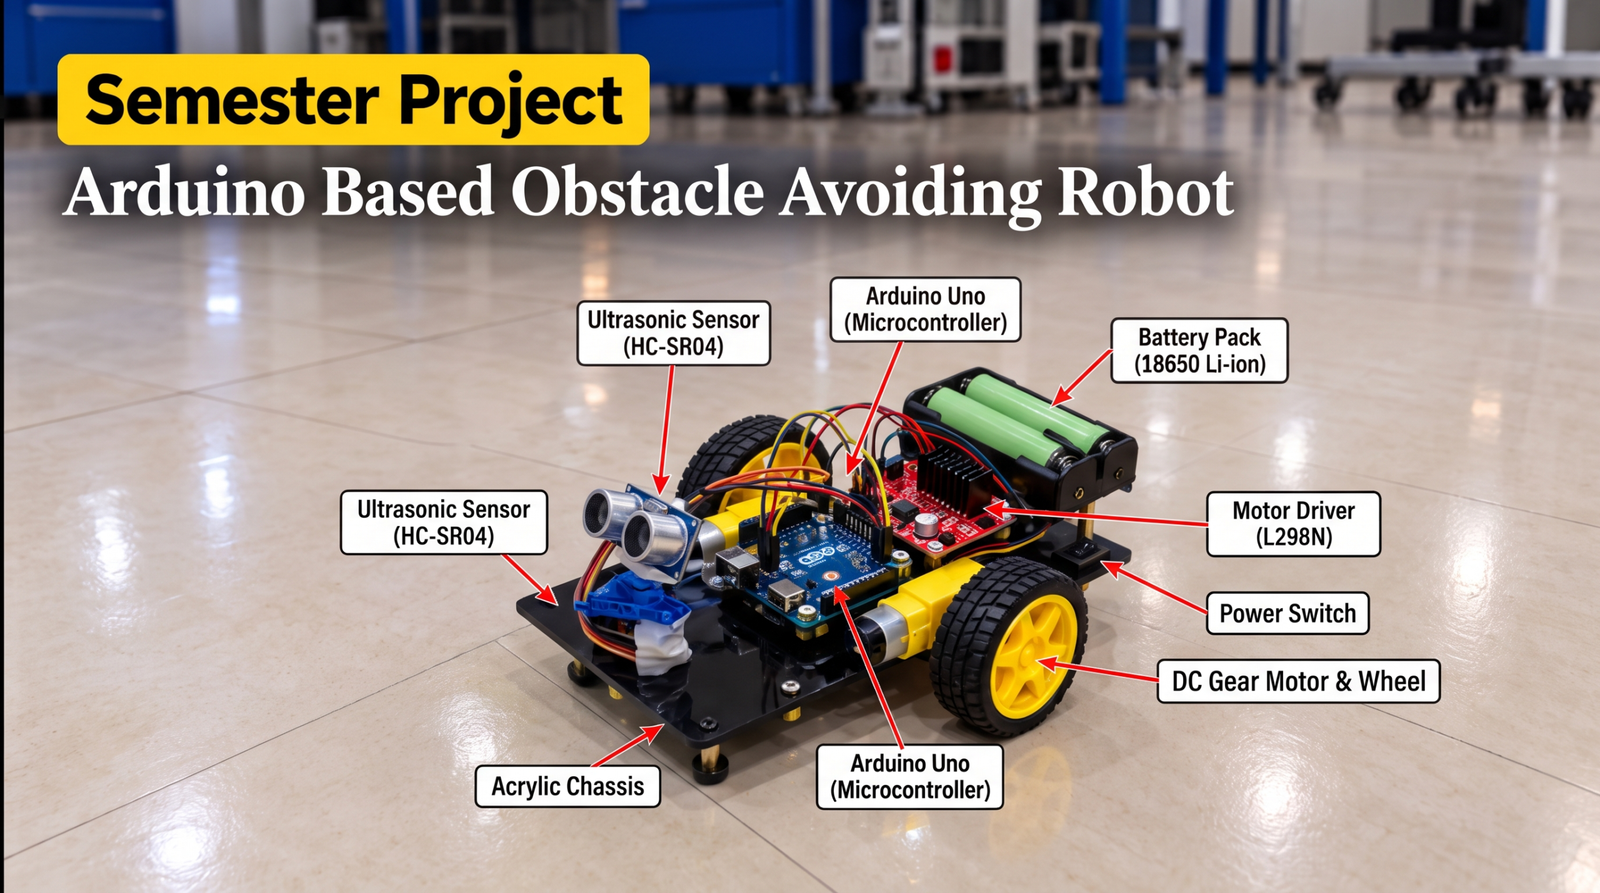
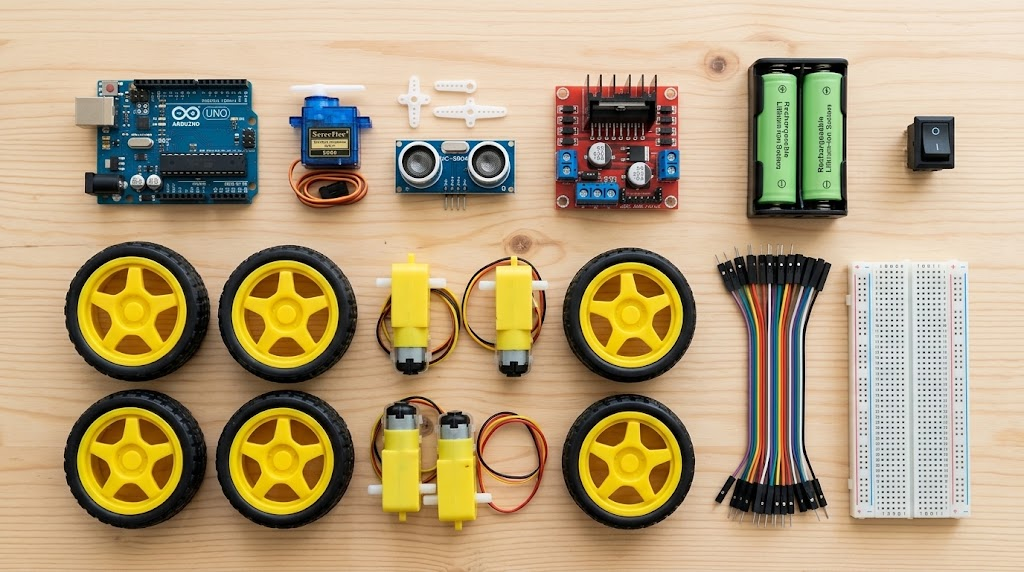
- Microcontroller: Powered by the Arduino Uno (ATmega328P), serving as the central processing unit to read sensor data and command motor outputs.
- Sensors & Actuators: Equipped with an HC-SR04 Ultrasonic Sensor for precise distance measurement, mounted on an SG90 Servo Motor to enable wide-angle environmental scanning.
- Drive System: Utilizes an L298N Dual H-Bridge Motor Driver to independently control the speed and rotational direction of four DC gear motors.
- Power & Chassis: Powered by a high-energy-density 18650 Lithium-Ion battery pack to ensure stable voltage for both the microcontroller and the high-current motors.
Mechatronics & Embedded Programming
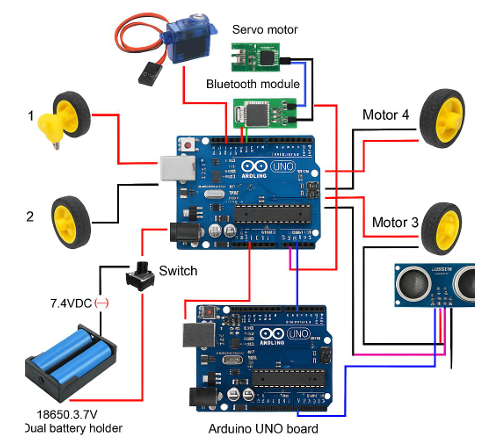
- The control logic was programmed in C++ using the Arduino IDE, integrating NewPing.h for efficient, high-speed sonar pinging and Servo.h for precise angular sweeps.
- The algorithmic workflow dictates that the robot continuously scans its forward path. If an obstacle is detected within a 30 cm threshold, the system immediately commands the L298N driver to halt the motors.
- The SG90 servo then sweeps the ultrasonic sensor to the left (160°) and right (20°) to measure available space. The Arduino evaluates these readings, calculates the optimal route, and executes a precise turning maneuver toward the clearest path.
Applications & Future Scope
- This project successfully synthesizes hardware assembly and logic programming to create a reliable automated system, showcasing strong competencies in robotics, circuit integration, and algorithmic problem-solving.
- The architecture is highly scalable; future enhancements can include the integration of AI for advanced path planning, IoT modules (Wi-Fi/Bluetooth) for remote telemetry, and infrared sensors for edge detection and complex mapping.
Conclusion
The development of this autonomous robot highlights the powerful capabilities of Arduino-based embedded systems. By successfully bridging the gap between hardware wiring and software control loops, the project proves the viability of cost-effective automation solutions applicable to a wide range of modern robotic engineering challenges.